Monday, November 22, 2010

Screw Driver Mysteries.....

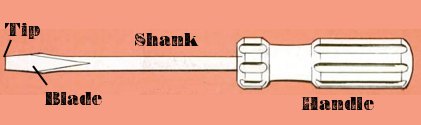
Tightening screws can be bugging at times. You keep rotating the screw driver and the screw refuses to tighten!!


With the Screw Driver Mysteries solved, you can actually get the task done in a few seconds rather than minutes. I have listed a few for you:

1. Right Direction : All screws tighten in the clockwise direction and loosen in the anti-clockwise direction.

2. Right Tip: The tip of the screw driver should be almost equal to the size of the screw's head. This makes sure all the force you apply is directed at the right place.

3. Right Size: Choose your screw driver depending on how much power you require. For more power, use one with a short shank (the part between the tip and the handle) .

If you have resolved any more Mysteries, feel free to share them!

Saturday, November 06, 2010

Diwali Celebration


We had a great Diwali Celebration at our office on Thursday. As it turns out, we are not only good at designing Robots but also at Rangolis :). Well find it hard to believe check the picture below:

Tuesday, September 28, 2010

IRC 2010 Problem Statement

Hey Friends!

So you are worried about the IRC-2010? Well, the arena dimensions are here. This would give help in designing the robot according to the track's dimensions.
.

Sunday, September 05, 2010

Magical Torque......

In the post At the Right Angle, I talked about the definition of force and its application in Robotic Arm and Base. In today's post, I will talk about how Torque can create magic!!

We need to apply a bit of mathematics here to understand the magic.

Torque is calculated by the formula:
T = F*d

T is the torque
F is the force applied perpendicular (at 90 deg.) to the axis
d is the distance

By using the above formula, we can calculate torque for Geared systems. Lets, take the example of the gear system below:


Here, we have attached a gear system with a pulley. Let us assume the load on the pulley is 1 kg and the diameter of the pulley is 1 inch. Then the torque would be:

T= F* d = 1 kg * 1 inch = 1 kg-inch

Now, what would be the torque on the Big Gear? The torque transferred on the Big Gear would also be 1kg-inch. This is because the torque remains constant on the shaft, and is transferred to the big gear.

The next step is to calculate the force on contact point B. We know the Torque is 1 kg-inch and the diameter of the Big Gear 1 inch. So,

F = T/d = 1 kg-inch * 1 inch = 1 kg

So now lets calculate the torque on the motor. The force on the Small Gear is 1 kg and its diameter is 1/4 inch. The resultant torque on the motor shaft is:

T= F * d = 1 kg * 1/4 inch = 1/4 kg-inch

Did you see the magic happen?
Torque at motor = 1/4 kg - inch
Torque at Pulley = 1 kg- inch!!

Torque increases magically, but only if we put the gear systems right!

Sunday, August 29, 2010

Innovation is Here!

Hi Friends,

Here is an innovative robot designed by Sahil Rastogi (RDPS). This is a Robotic Claw that can grip objects.


If you have some interesting designs to show to us, mail us at bulo@buildingblocks.in with your name, school and age.

Sunday, August 22, 2010

The Powerful Trio

Okay, so your robotic arm does not pick heavy objects and you cant keep adding Gear Systems (there are really expensive!). So what do you do?

Maybe, you should use the Powerful Trio - Force, Surface Area and Pressure into use. Let me first give you the definitions of the three concepts:

Surface Area: A mathematical term that tells us how much surface is exposed
Force: Any external influence that makes an object move.
Pressure: Force applied per unit area.

Using all three, you can spread the force to an area. Lets take an example of this object lifter:


This lifter has a cool gear system. But notice the Arm is attached through the small axle. It has a small area of contact on the Long L Clip.

Less the surface area, more is the net pressure on the area of contact. And the resultant force on the shaft of the motor makes it difficult to pick objects.

Here's the solution. Design the robot in such a way so that the pressure is distributed to different contact points.


This Object Lifter can lift greater load as we now have two points of contact where pressure is well distributed.

The Powerful Trio definitely makes your robot more powerful!!